Intelligent Soft Wearables
Bridging Disciplines Towards Soft Wearables for Humans and Robots.
ICRA 2027 Workshop Proposal - May 24 or 28 (half day) @ Seoul
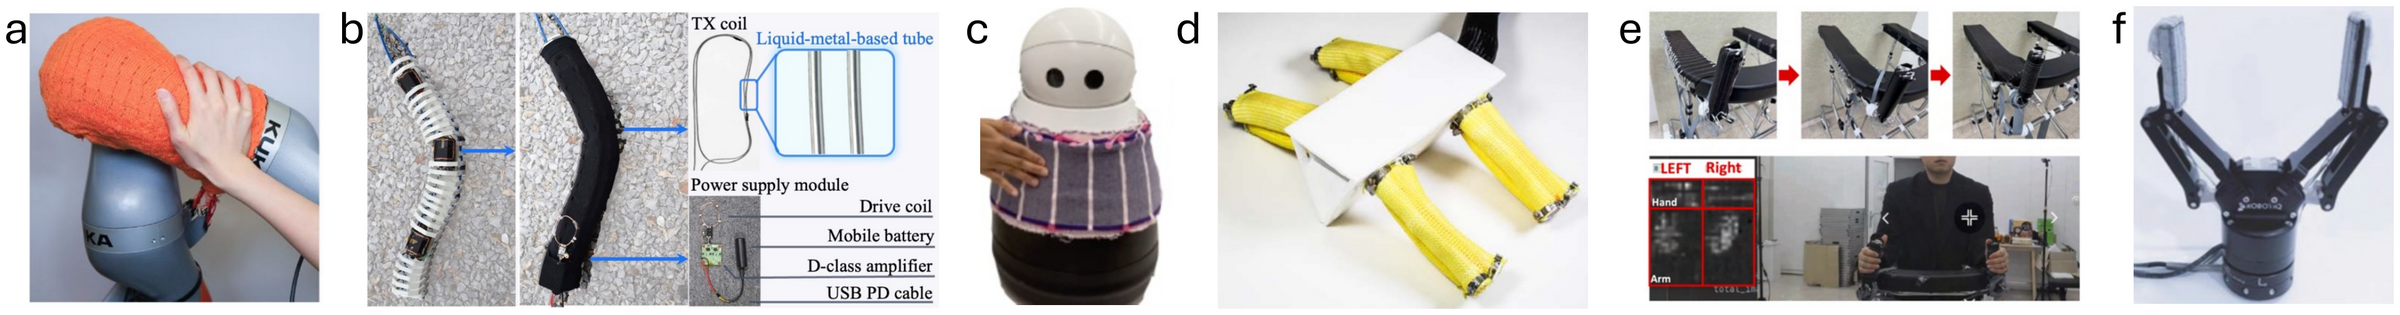
Intelligent soft wearables for robots: (a) conformal tactile textiles, (b) inner-wireless snake robot, (c) machine-knitted tactile skin, (d) knitted pneumatic actuators with integrated sensing, (e) intelligent walker with tactile and IMU sensing, and (f) adaptive tactile interaction transfer.
Intelligent Soft Wearables for Robotics
Soft wearables are soft, flexible, lightweight, and comfortable, so they can be attached seamlessly to objects of different shapes to collect data and provide feedback. Owing to these characteristics, they are no longer worn only by humans; robots are increasingly equipped with them. For instance, they serve as robot skins that help robots interact with objects and their surroundings, and wearable robots incorporate them to understand the physical state of humans while providing comfort and seamless integration.
This is timely because physical context (e.g., contact, force, and motion) is critical for robots in the era of physical AI. Soft wearables let robots digitize this context in a scalable way, and AI can analyze it to optimize robot movements or provide feedback to humans. Realizing this potential requires interdisciplinary knowledge spanning sensors, AI, and robotics: advances in manufacturing and sensing improve integration, AI makes wearables intelligent, and robots act on the resulting physical context information. This workshop aims to bring these three communities together.
The workshop will host demos, posters, and interactive discussion sessions around these topics:
- Soft wearables: design, fabrication, AI-based information extraction, and applications
- Robots with soft wearables: control, manipulation, and movement optimization
We aim to explore the questions:
- How to make soft wearables accessible to the robotics community?
- How to leverage intelligent soft wearables to capture, analyze, and use physical context?
- How to integrate intelligent soft wearables for robot control and feedback, to support intuitive, safe, and effective interaction?
Keynotes
Two keynote speakers will be announced soon: one robotics expert and one wearable sensor expert.
Call for Contributions (tentative)
We invite researchers and practitioners from robotics, wearable sensing, and AI to share their work:
-
Calling for live demos (the best!) and posters: 2-page extended abstracts (excluding references), using the double-column IEEE conference template
-
Non-archival: accepted abstracts will be shared on this website, and work under review or previously published elsewhere is welcome
-
Submissions through OpenReview (link and dates coming soon)
-
Light review process: each submission is reviewed by 2 members of the organizing committee
-
All accepted contributions are presented during the Demo and Poster Session (up to 20, in two groups so that every presenter can also visit others’ work)
-
Workshop participation is open to everyone, as long as the venue space allows: informal demos from attendees are also welcome, without submission
Topics of interest include (but are not limited to):
- design and fabrication of soft wearable sensors and actuators, for humans and robots
- robot skins and tactile sensing for manipulation
- wearable robots and physical human-robot interaction
- AI-based extraction of physical context (contact, force, motion) from soft wearables
- control and movement optimization informed by soft wearables
- scalable manufacturing and integration of soft wearables
- feedback to humans from intelligent soft wearables
Previous Workshops
- ACM UbiComp 2026, Shanghai, China
- ACM UbiComp 2025, Espoo, Finland
- ACM UIST 2024, Pittsburgh, USA
If you have any questions, please contact SoftWearables(AT)mit.edu.
News
| Nov 02, 2026 | Workshop proposal submitted to ICRA 2027 (Seoul), expanding intelligent soft wearables to robotics. |
|---|---|
| Oct 12, 2026 | Successful UbiComp 2026 workshop hosted in Shanghai! Thanks to our keynote speakers and all participants. |
| Oct 13, 2025 | Successful UbiComp 2025 workshop hosted in Espoo! Fruitful and fun discussion on intelligent soft wearables. |
| Oct 13, 2024 | Successful UIST 2024 workshop hosted in Pittsburgh! We had a full room discussing democratizing intelligent soft wearables. |